Executive Summary
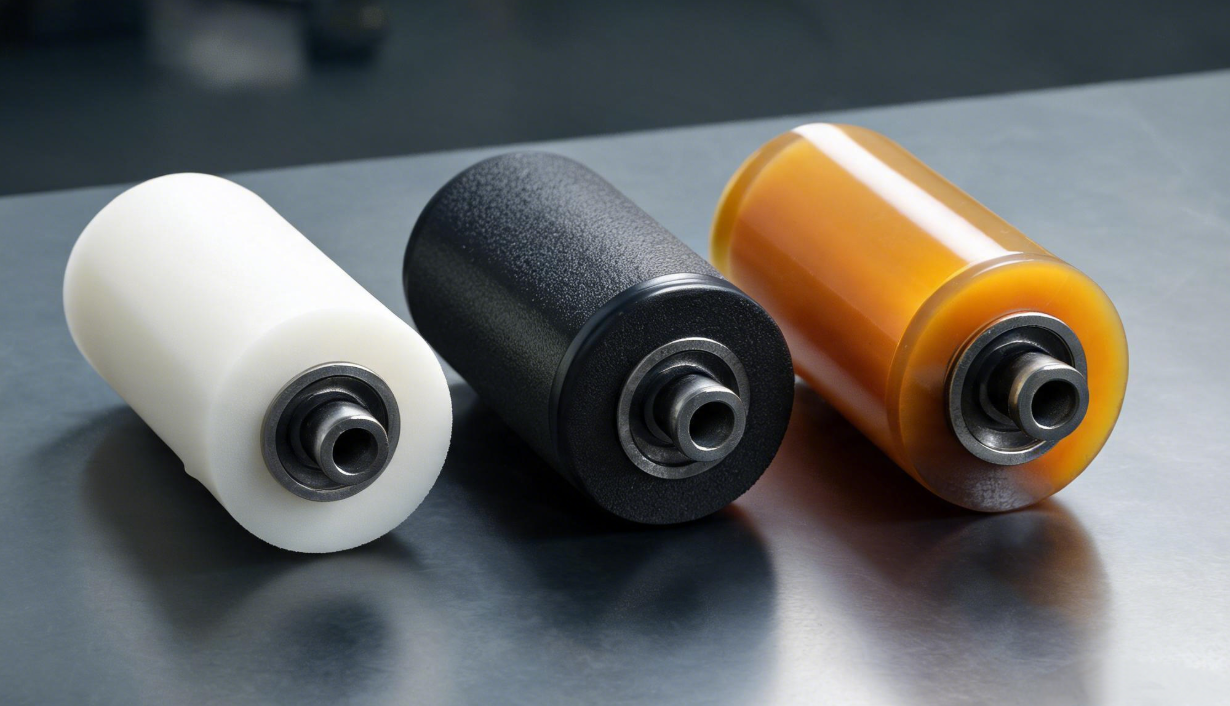
An AGV that drifts off its path, or that stops in the wrong place, has three families of possible causes: navigation and calibration (sensor mounting angle, calibration parameters, floor marker accuracy), mechanical structure (frame deformation, suspension condition, assembly error), and the executing components - above all the wheels. The wheel-side problem is easy to underestimate because it is silent. No alarm is raised and no error code is logged; the only visible sign is a vehicle that slowly wanders off the line. When everything electronic has already been checked, wheel geometry is often where the remaining error lives.
Five geometric indicators define how a wheel behaves under a moving vehicle: diameter consistency between the wheels of the same machine, tread roundness, radial runout, face runout of the hub, and concentricity between the tread and the wheel core. Together they determine two things that matter to every AGV - heading-hold capability and odometry accuracy. Diameter mismatch is the most deceptive of them. A 0.5 mm difference between the left and right drive wheels, a relative difference of only 0.25%, accumulates an estimated 2.9 degrees of heading deviation and roughly 25 cm of lateral drift over a 10 m straight run when both sides are commanded to the same speed.
Closed-loop navigation does not remove wheel error; it converts it into observable symptoms. Once geometric error enters the control loop, it typically appears as an S-shaped trajectory with repeated corrections, faster wear on one wheel because that wheel performs more of the corrective work, and a falling first-attempt success rate at docking stations and charging posts. That is why a higher grade of navigation accuracy raises, rather than lowers, the precision demanded from the wheel.
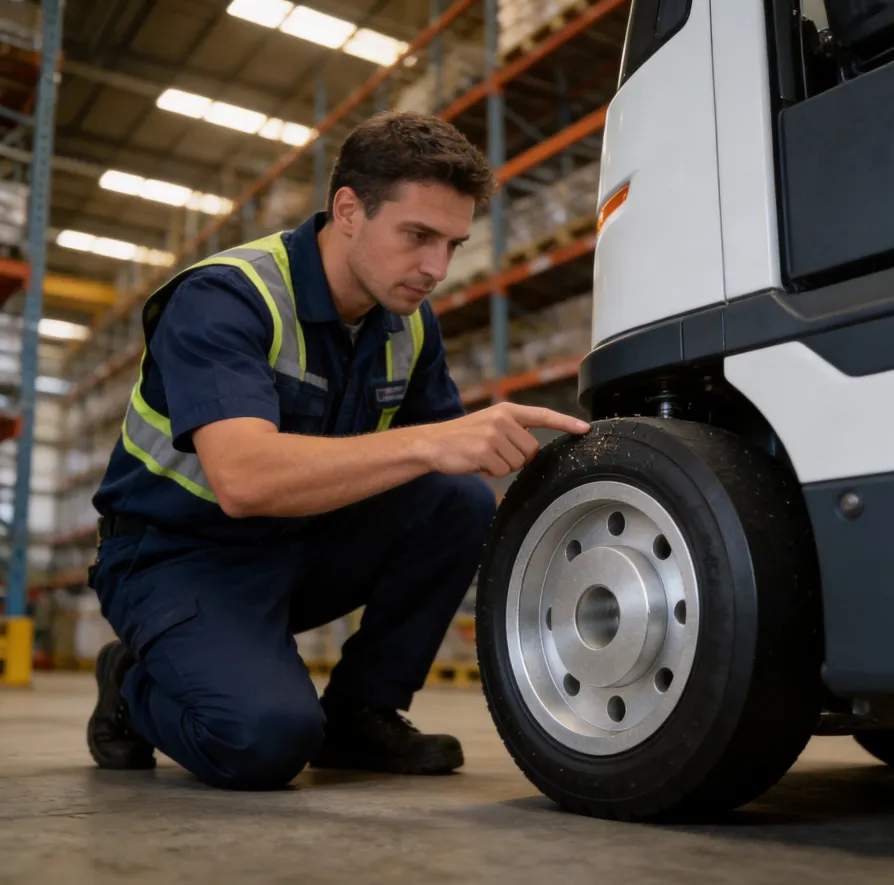
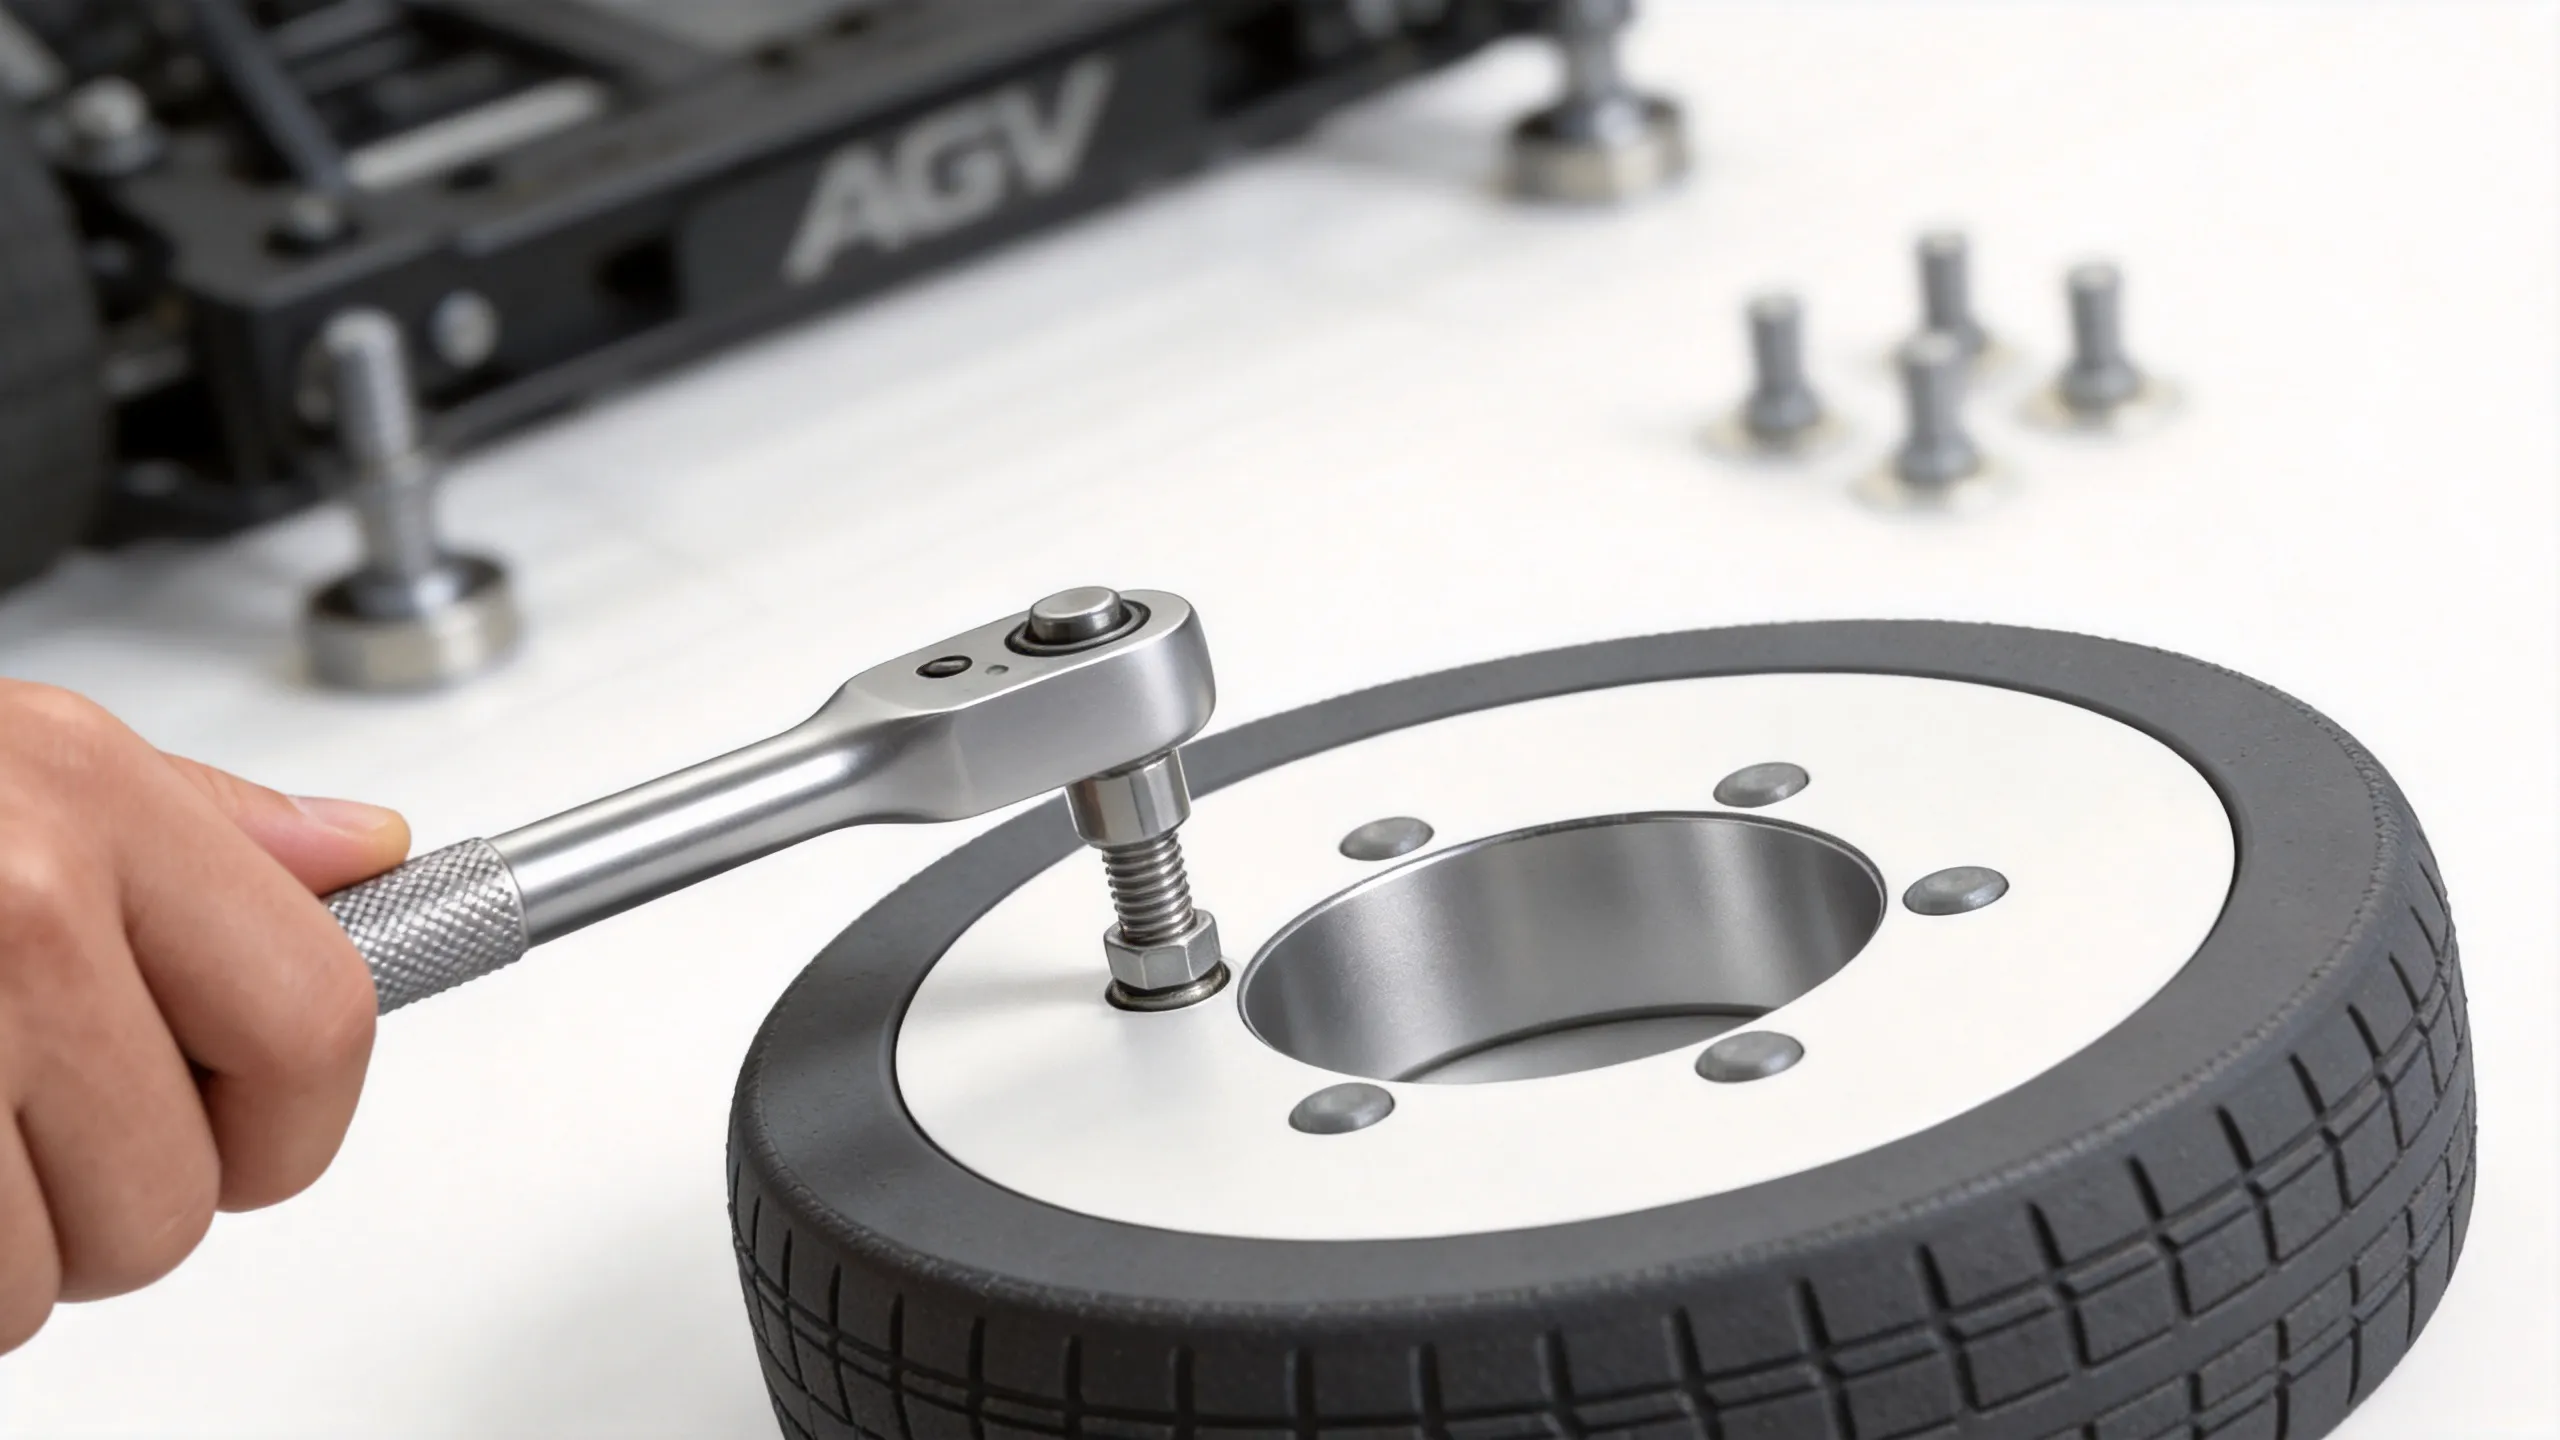
This guide summarizes the mechanics behind wheel-induced drift, breaks the causes into six root categories, and gives you an executable five-step field method: visual inspection, diameter measurement, runout dial indication, hardness comparison, and a road test with odometry recalibration. It also provides a precision control checklist that can be written directly into purchasing and acceptance specifications. The final section takes the supplier-side view. Drift is a precision problem that is hard to remedy after the fact but controllable beforehand, and mapping each root cause to the process where it originates and the inspection gate where it is intercepted is the practical answer. HANKE's process control and batch inspection records are used here as a worked example of the verifiable data a customer can request.
 EN